01 / DAY 1 · EXPLORE
Find the other elevator.
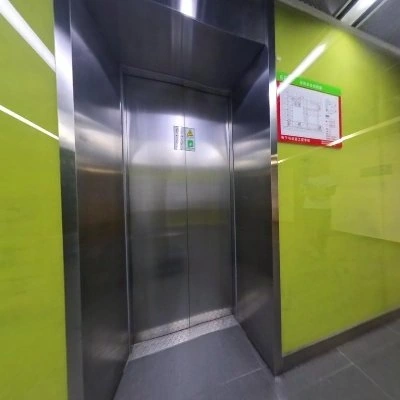
Explore approximately 87 m from room 625 to the opposite elevator and retain meaningful places along the route.
A little curiosity. A world of experience.
A unified harness for lifelong embodied navigation
with hybrid action space and persistent memory.
† Corresponding authors
Tongji University · Shanghai, China
Navigate with intention. Interact with curiosity. Evolve through experience.
navigate_candidate01 / THE IDEA
A robot should do more than follow the next command. It should choose a useful way forward, ask when something is unclear, and carry that understanding into its next visit.
navigate_candidate / navigate_pixel / navigate_object / stepAgent chooses · Adapter executesA movement intention can be expressed as a geometric candidate, a selected floor pixel, an object estimate, or a short discrete action. Actual observations and motion feedback inform the next decision.
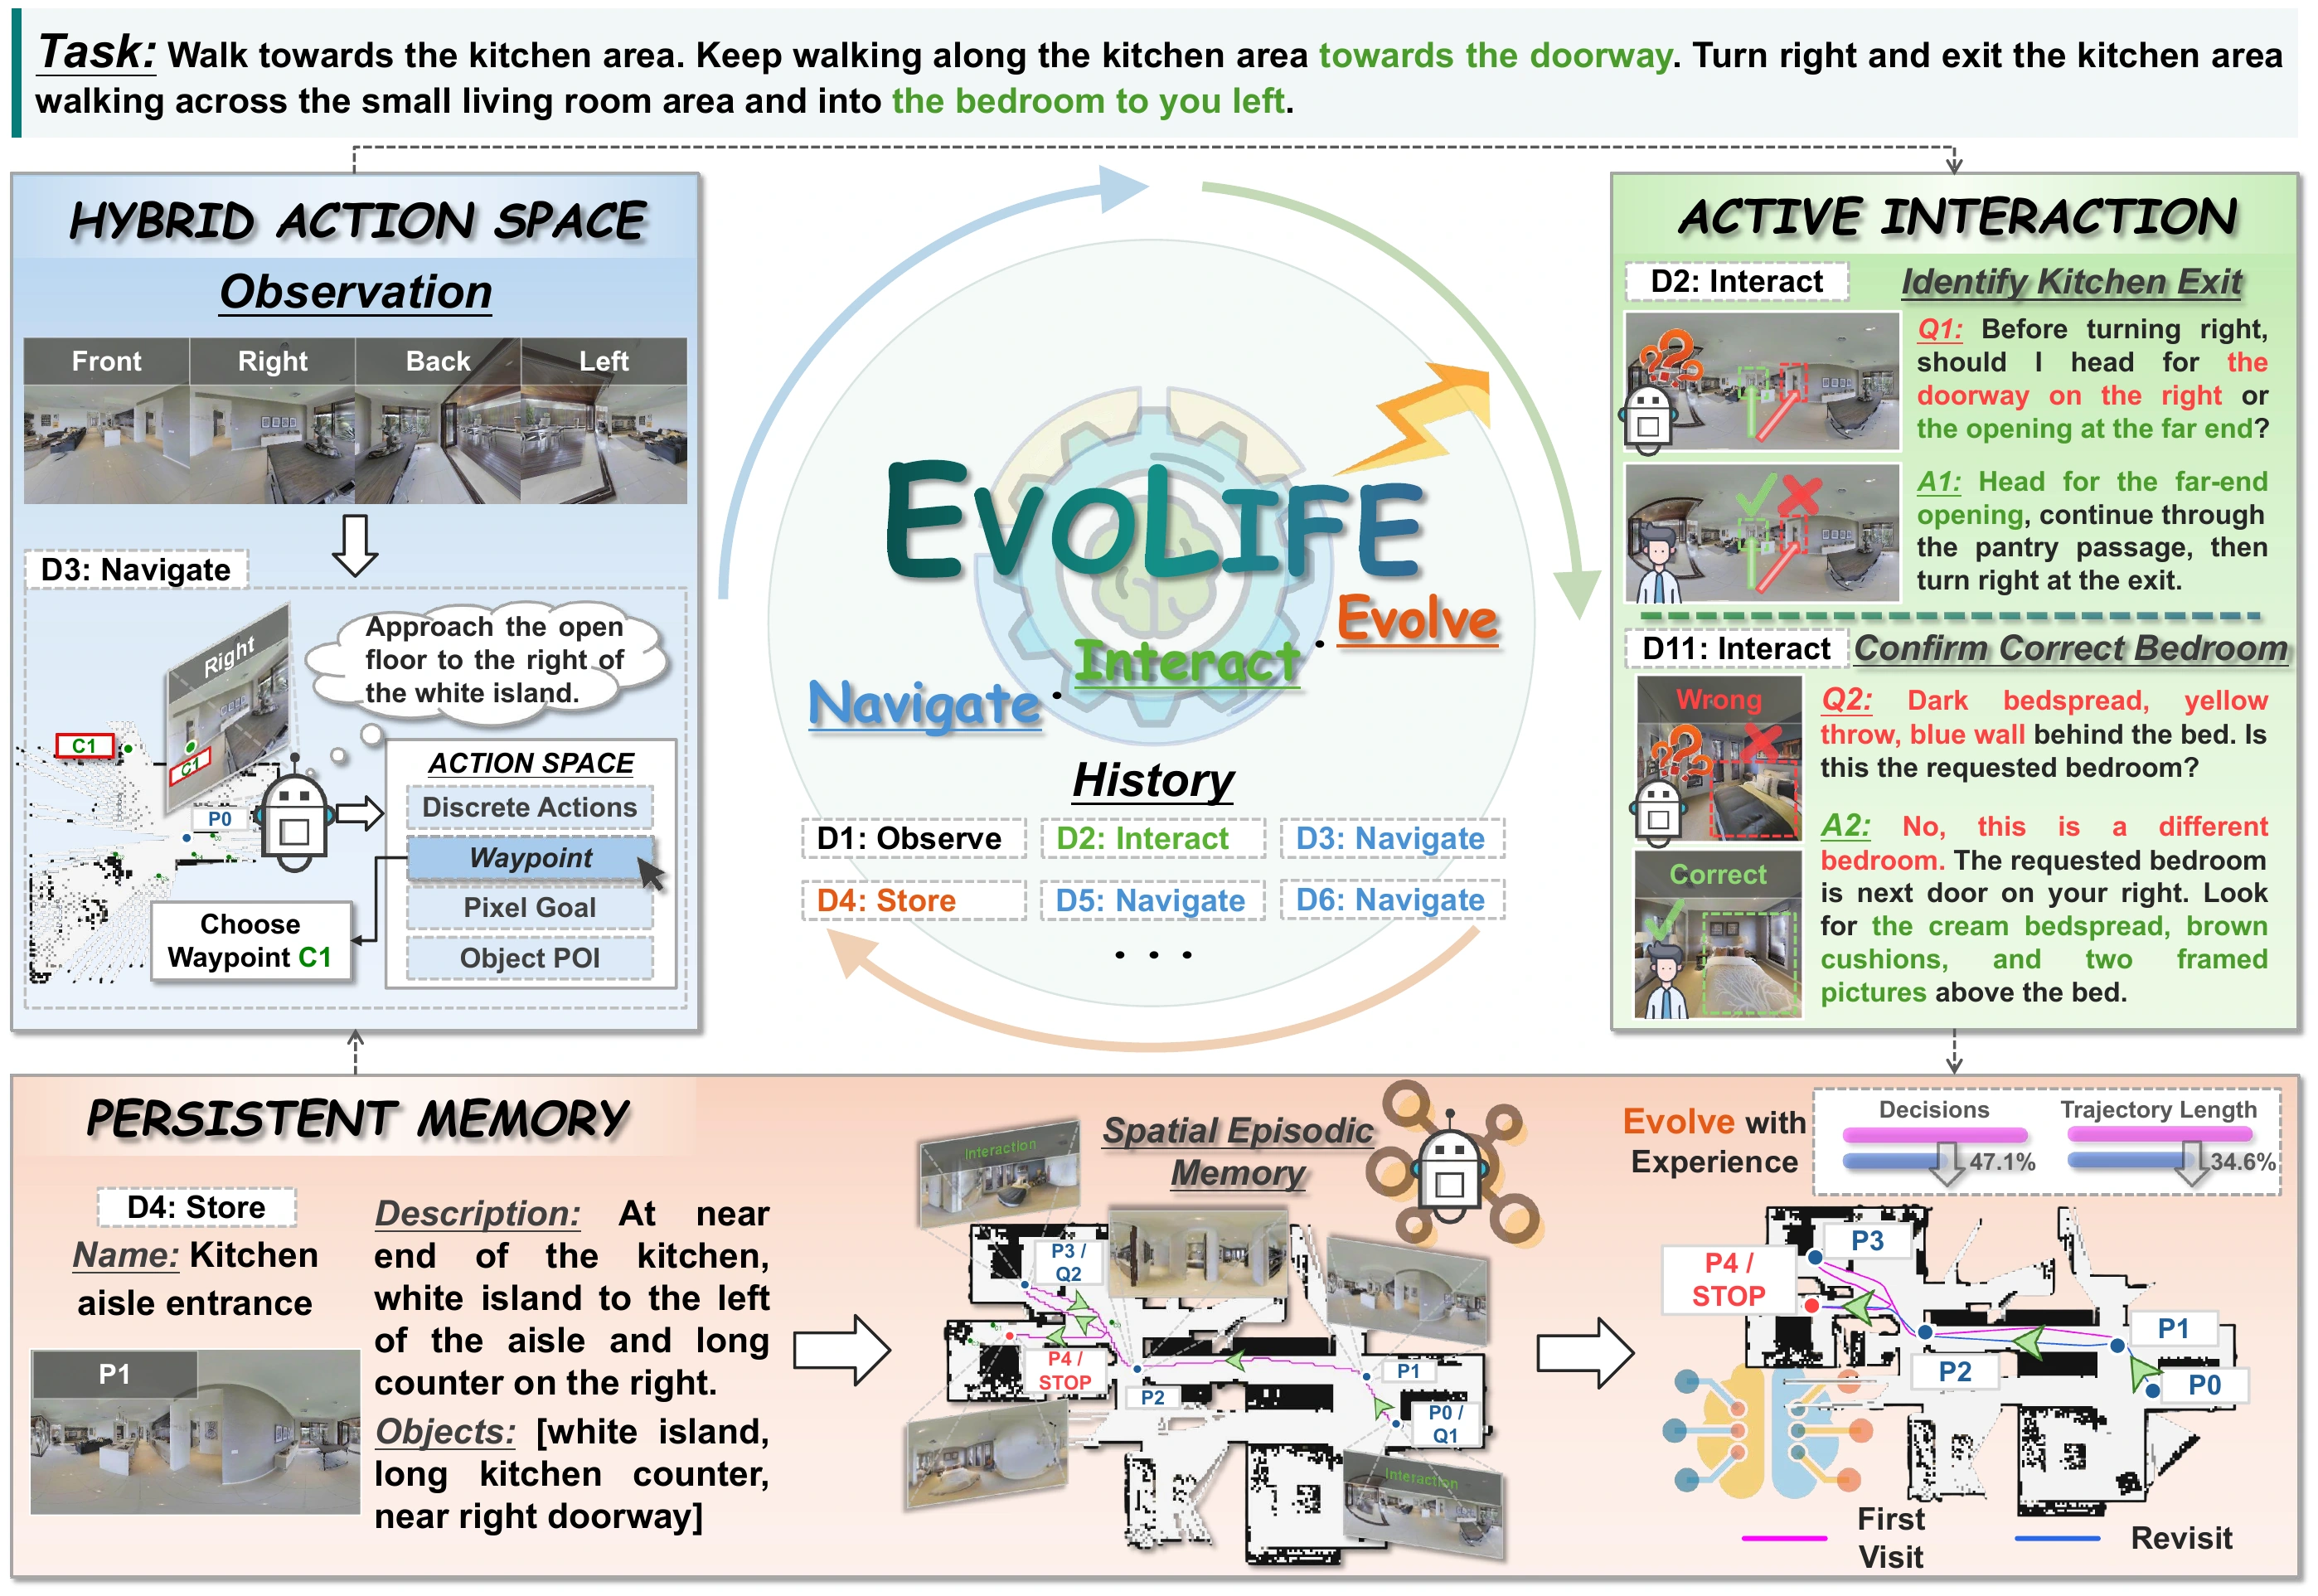
EVOLIFE connects hybrid actions, active interaction, and persistent spatial memory within one embodied navigation harness. Each encounter can inform the current decision and contribute experience for subsequent tasks.
02 / FIELD NOTES
Explore navigation across eight benchmarks. Watch the views, maps, selected tools, and agent-initiated conversations come together.
03 / OUT INTO THE WORLD
A corridor becomes familiar. A door closes. A new day begins. Multi-day physical navigation brings action, help-seeking, and remembered places into the same ongoing experience.
Explore approximately 87 m from room 625 to the opposite elevator and retain meaningful places along the route.
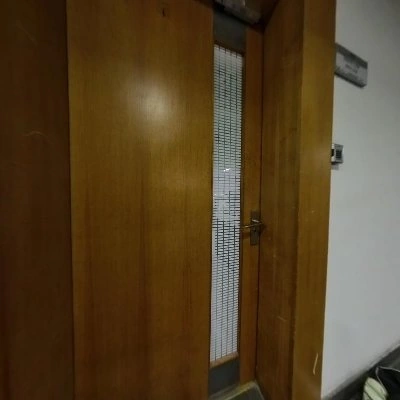
Ask for help, verify the open passage, and continue to the remembered destination.
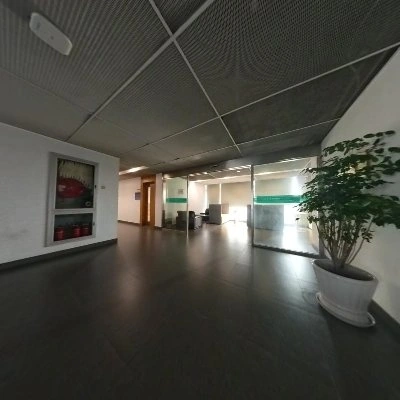
Restore the spatial context and navigate approximately 60 m to the remembered glass office on the following morning.
04 / THE EVIDENCE
Eight benchmarks span language-guided routes, object search, interactive instance navigation, and continuous multi-task sequences.
SR on first visits to unseen environments: R2R-CE, RxR-CE, HM3D-OVON and HM3D v2.
SPL on matched revisits without new interaction.
LHPR-VLN / GOAT-Bench, 50 full sequences each.
Loading comparison results…
A CLOSER LOOK AT THE NUMBERS
05 / A CLOSER LOOK
EIGHT BENCHMARKS / EIGHT ENCOUNTERS
Read the task. Follow the growing map.
See how each observation becomes a tool choice.
Loading cases…
Loading the eight qualitative examples…
TAKE THE NEXT STEP
A new encounter. A better way forward.
Read the paper on arXiv. Code is coming soon.
@misc{sheng2026askevolveunifiedharness,
  title = {Ask to Evolve: A Unified Harness for Lifelong
           Embodied Navigation with Hybrid Action Space
           and Persistent Memory},
  author = {Kai Sheng and Liuyi Wang and Jinlong Li and
            Haojie Dai and Chengju Liu and Qijun Chen},
  year = {2026},
  eprint = {2610.39446},
  archivePrefix = {arXiv},
  primaryClass = {cs.RO},
  url = {https://arxiv.org/abs/2610.39446}
}
RAIL · Tongji University
Robotics and Artificial Intelligence Lab